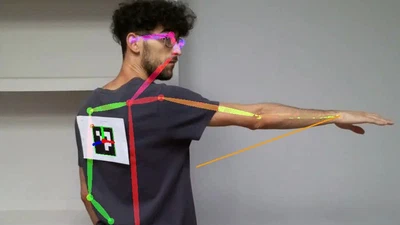
Drone control based on vision and gestural programming
This project integrates gesture recognition as a drone control mechanism to provide the drone with a certain degree of autonomy respect to its operator, which is specially useful …
alvaro-ayuso
This project integrates gesture recognition as a drone control mechanism to provide the drone with a certain degree of autonomy respect to its operator, which is specially useful …

The objective of the system is to control a baxter robot using the kinect V2 and tis body structure extraction modules (body tracking) under the ROS (Robot Operating System) …


This work presents a real-time clustering technique that takes advantage of the unique properties of event-based vision sensors. Our approach redefines the well-known mean-shift …
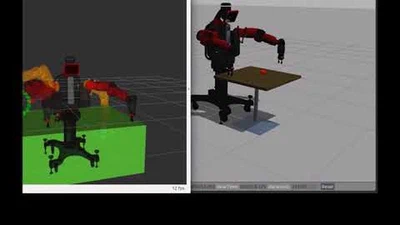
The project presents various demonstrations of pick and place tasks with the Baxter research robot, with object recognition and manipulation with objects of various shapes, sizes, …

This project shows the development of various classification tasks in static and dynamic environments with the Baxter robot based on color, using also a conveyor where pieces are …